


Why controlled ankle motion is not the same as energy return
Walking may look simple, but the ankle performs a remarkable amount of work with every step.
From the moment the heel contacts the ground, the foot and ankle help control loading, support the body as it moves forward, manage mechanical energy and contribute to propulsion during push-off.
Reproducing these functions in a prosthetic foot is a significant engineering challenge. Unlike the biological ankle, a passive prosthetic foot has no muscles or nervous system to actively generate and regulate movement. Instead, different mechanical technologies are used to reproduce aspects of ankle function.
Hydraulic damping is one of these approaches.
By forcing fluid through restricted passages, a hydraulic mechanism provides resistance that controls how quickly an articulated ankle moves. This can support motion control and adaptation to different walking conditions.
Yet controlling ankle movement and returning mechanical energy are two fundamentally different functions.
A hydraulic damper dissipates energy as it controls motion. It does not itself store and return energy like an elastic spring or generate additional power for push-off.
So what can hydraulic prosthetic feet reproduce, where do they offer benefits, and what are their mechanical limitations?
Hydraulic control has been used in prosthetic knees since the development of early hydraulic knee mechanisms in the 1950s. Commercial passive hydraulic ankle-foot systems appeared much later, with a widely recognised system introduced in 20092.
In prosthetic knee design, hydraulic mechanisms made it possible to regulate joint movement through adjustable resistance.
This approach is particularly relevant because the biological knee performs substantial energy-absorbing functions during walking. By controlling joint movement, hydraulic systems can help manage loading and movement during different phases of gait.
Manufacturers subsequently applied similar principles to prosthetic ankles.
The two joints, though, serve different mechanical functions.
The knee plays an important role in controlling movement and absorbing energy. The biological ankle also performs these functions, but it contributes substantial positive mechanical work during late stance, supporting propulsion through muscular power generation and elastic energy return1.
Applying hydraulic technology to the ankle therefore introduces a different set of biomechanical considerations.
For clarity, this article focuses on passive and microprocessor-controlled hydraulic ankle-foot systems. Microprocessor-controlled systems can dynamically adjust hydraulic resistance, but they do not add propulsive energy unless the device also incorporates a powered actuator.
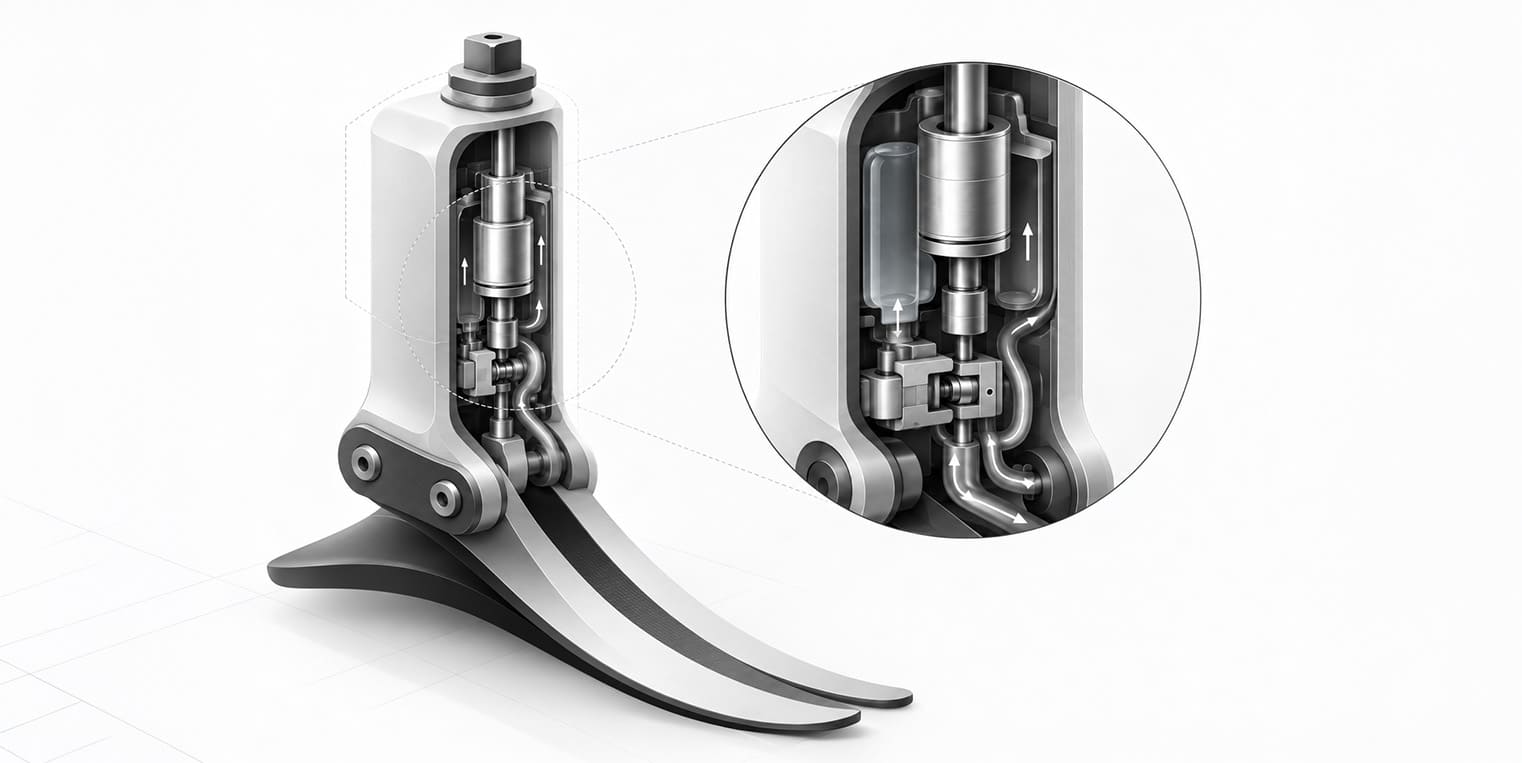
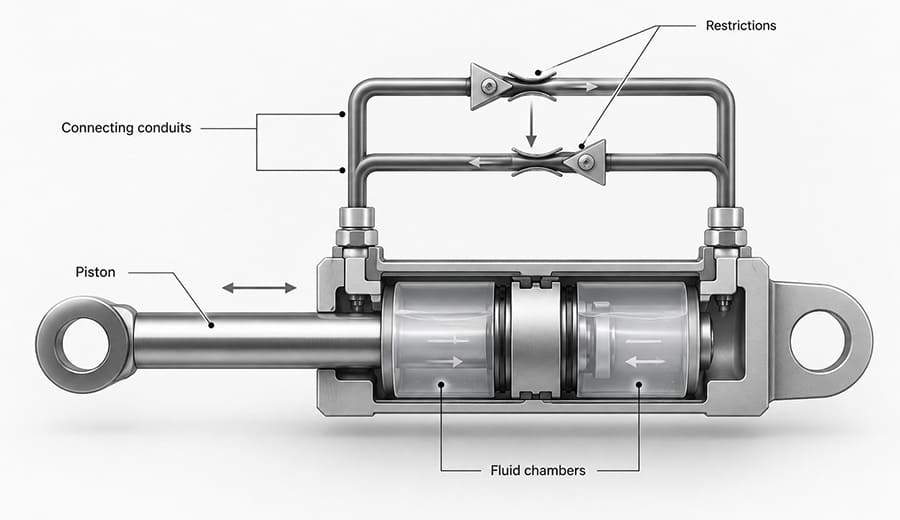
A simple way to understand hydraulic damping is to imagine a syringe filled with fluid.
When the piston moves, fluid must pass through an opening. A large opening allows relatively easy flow, whereas a smaller one creates greater resistance and makes movement more difficult.
A hydraulic prosthetic ankle follows a similar principle.
A typical mechanism includes:
As the ankle moves, the mechanism displaces fluid through these passages. The resulting resistance opposes the movement and helps regulate its speed.
This resistance is known as hydraulic damping.
Hydraulic ankle-foot systems may provide separate resistance settings for plantarflexion and dorsiflexion.
Plantarflexion refers to the downward movement of the foot, particularly relevant after heel contact. Dorsiflexion describes the upward movement of the foot relative to the shin as the body progresses forward.
Adjusting hydraulic resistance allows a prosthetist to influence how the ankle responds during these movements.
The mechanism itself does not actively drive the ankle. It responds to externally applied forces, regulating motion as the user walks.
In practice, hydraulic damping is often combined with other mechanical elements. Many hydraulic feet incorporate flexible heels, keels or carbon-fibre structures that contribute to support, rollover and elastic energy return2.
These components work alongside the hydraulic unit, each performing a different mechanical function.
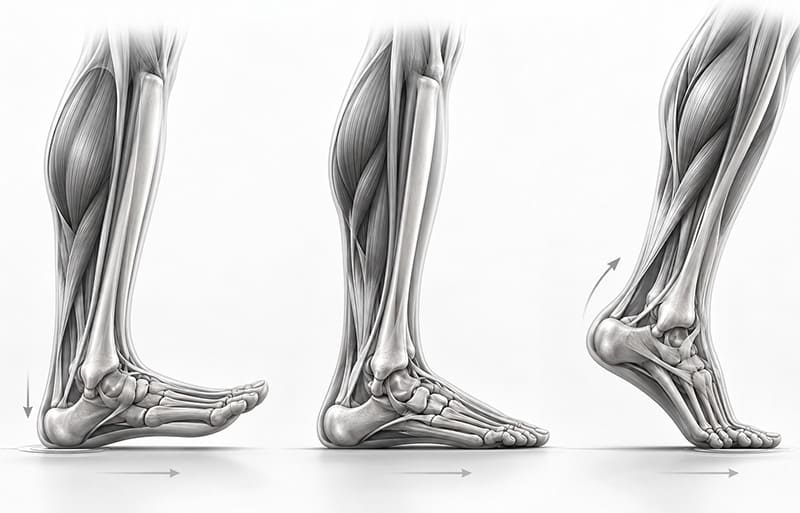
The mechanical role of the biological ankle changes throughout the gait cycle.
During early stance, it helps absorb energy and control movement. As the body progresses forward, ankle motion and muscle-tendon structures contribute to stability and mechanical energy management. During late stance, the ankle generates positive mechanical power that contributes to propulsion1.
Examining these phases individually reveals where hydraulic ankle-foot systems can reproduce aspects of natural ankle behaviour and where their mechanical characteristics differ.
1. Heel contact: absorbing and controlling energy
When the heel contacts the ground, the ankle typically moves into plantarflexion.
The muscles controlling this movement perform negative mechanical work, helping regulate the lowering of the foot toward the ground. Together with knee movement, soft tissues, footwear and the walking surface, this contributes to a smooth transition into weight acceptance.
How does a hydraulic foot respond?
Hydraulic damping is well suited to controlling this type of movement.
As the prosthetic ankle plantarflexes, fluid resistance helps regulate how quickly the foot moves toward foot-flat.
This can contribute to smoother loading and a more controlled transition after initial contact, reproducing an important aspect of the biological ankle's energy-absorbing role.
Once the foot is on the ground, the body continues moving forward.
The tibia progresses over the foot while the ankle moves into dorsiflexion. This contributes to rollover, the body's progression over the supporting foot.
At the biological ankle, muscles and tendons regulate this movement while managing mechanical energy.
How does a hydraulic foot respond?
An articulated hydraulic foot can accommodate dorsiflexion, using fluid resistance to control the rate of movement.
This controlled articulation may support adaptation to varying surfaces and inclines.
The available range of motion varies between devices and is limited by their mechanical design. Once the articulated mechanism reaches its limit, additional rollover must be accommodated by the compliant structures of the foot, other prosthetic components and the user's movement strategy.
The overall movement therefore depends on more than the hydraulic joint alone.
During late stance, the biological ankle produces substantial positive mechanical power.
This power results from the combined action of muscle-tendon structures, including muscular work and the release of previously stored elastic energy. It contributes to forward progression and the transition into the next step1.
How does a hydraulic foot respond?
A hydraulic damper resists movement and dissipates mechanical energy rather than generating power.
Some hydraulic prosthetic feet also incorporate elastic structures that store energy during loading and release part of it later in the gait cycle.
As a result, the complete foot may contribute passive energy return even though the hydraulic mechanism itself remains dissipative.
The distinction lies in which components manage movement, which store energy and how they interact throughout walking.
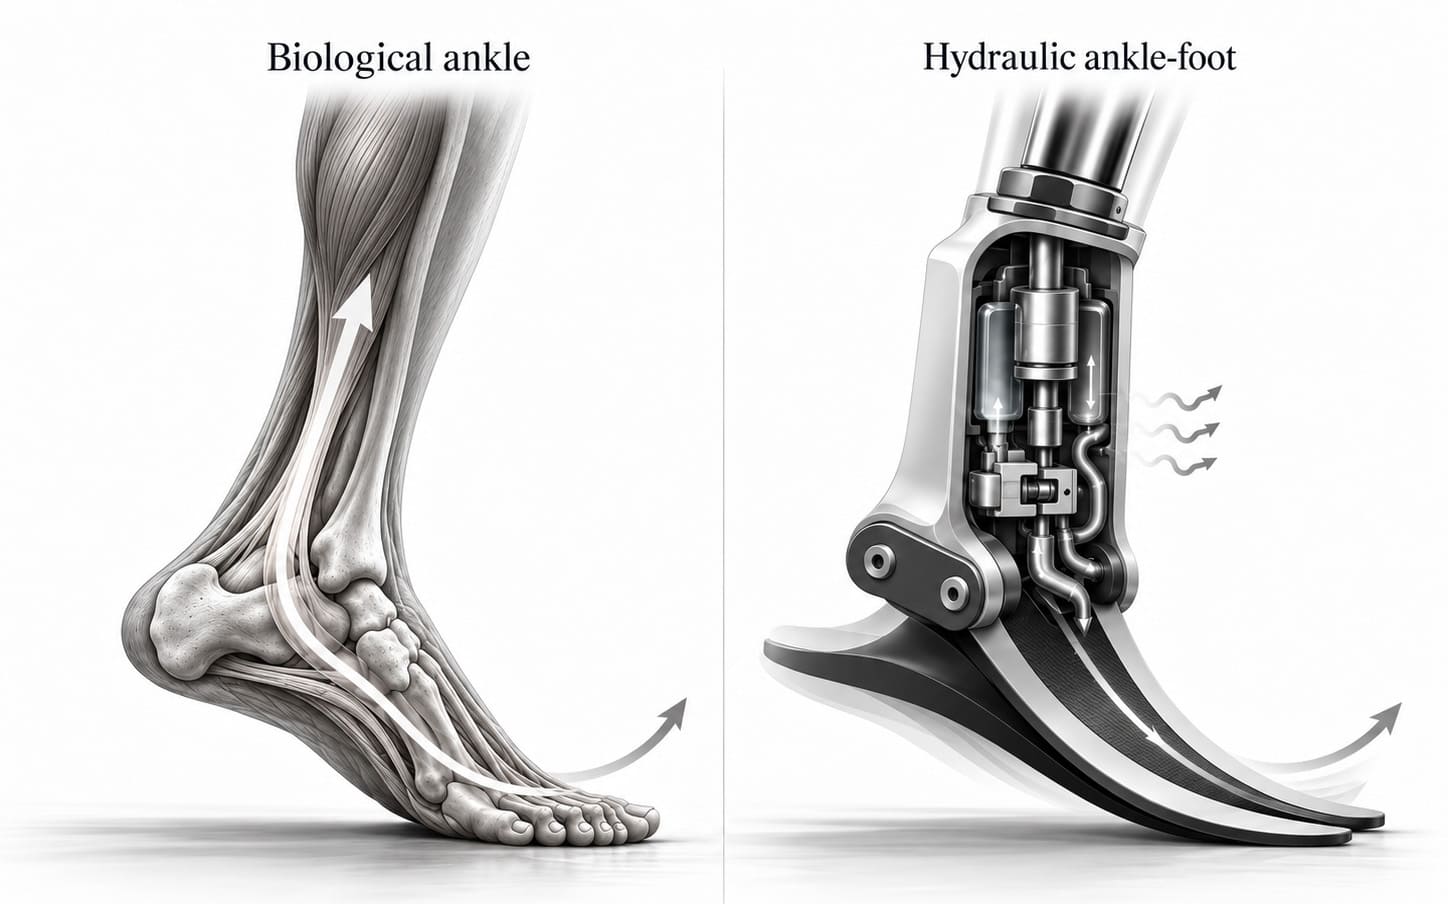
Hydraulic ankle-foot systems can offer meaningful functional benefits, particularly when walking conditions require adaptation.
By regulating plantarflexion and dorsiflexion, they may improve ankle motion control during loading, facilitate foot-flat positioning and support adaptation to slopes and other non-level surfaces.
Clinical research provides useful insights into these effects.
A study examining ramp descent found that a microprocessor-controlled hydraulic foot increased energy absorption at the prosthetic ankle-foot and reduced certain compensatory movements at the residual knee3.
A 2026 exploratory crossover study involving ten experienced transtibial prosthesis users compared two hydraulic feet with a conventional energy-storing-and-returning (ESR) foot4.
Both hydraulic feet increased minimum toe clearance on the prosthetic side across walking tasks. The most pronounced biomechanical and user-reported benefits appeared during non-level walking and standing tasks, with improvements in perceived comfort and physical effort under certain conditions.
The study also reported increased ankle-foot energy absorption with hydraulic feet, without consistent differences in fundamental spatiotemporal gait measures.
These results suggest that the benefits of hydraulic prosthetic feet are task-specific rather than universal.
Their mechanical design also involves trade-offs.
Hydraulic articulation operates within a limited range of motion, and energy dissipated through damping is unavailable for later elastic return. The extent to which this affects push-off depends on the interaction between the hydraulic unit and the other components of the foot.
The complete device, rather than any individual mechanism, ultimately determines its mechanical behaviour.
Hydraulic damping and elastic energy storage and return address different mechanical functions.
A hydraulic damper regulates motion by converting mechanical energy into other forms, primarily heat.
An elastic structure behaves differently. It deforms under load, temporarily storing mechanical energy before releasing part of it as it returns toward its original shape.
Neither passive mechanism adds net mechanical energy to the system. Each plays a different role in managing energy throughout the gait cycle.
These mechanisms can coexist within the same prosthetic foot. What matters is how their respective functions are coordinated by the overall design.
The architecture of a prosthetic foot determines how its mechanical components work together, influencing movement, stiffness, support and energy management.
This broader design challenge is explored in our article on prosthetic foot stiffness and why architecture matters.
Prosthetic foot technologies address different functional priorities. Their suitability depends on both their mechanical characteristics and the needs of the individual user.
Several considerations can guide the evaluation:
Selecting a prosthetic foot requires an individual clinical assessment that considers functional goals, component compatibility and available evidence. Where appropriate, trials of different technologies can help users and prosthetists evaluate their performance in real-world conditions5,6.
Hydraulic prosthetic ankles provide a valuable approach to motion control, particularly during initial contact and when adapting to inclined or uneven surfaces.
Yet ankle mobility represents only one aspect of biological ankle function. Mechanical energy management is equally important, and the way a prosthetic foot balances these functions depends on its overall architecture.
At Axiles Bionics, this principle has shaped the development of Lunaris.
Rather than relying on hydraulic damping, its articulated elastic architecture separates structural support, ankle mobility and elastic energy management, allowing complementary mechanical elements to fulfil different roles throughout walking.
Because reproducing ankle movement is only part of the challenge. How a prosthetic foot manages energy matters just as much.
A hydraulic prosthetic foot is an articulated prosthetic foot that uses fluid resistance to regulate ankle movement. It helps control plantarflexion and dorsiflexion during walking and may incorporate additional elastic structures for support and energy return.
Ankle movement drives fluid through restricted passages inside the hydraulic mechanism, generating resistance that regulates movement speed.
Depending on the device, resistance may be fixed, manually adjusted or dynamically controlled by a microprocessor.
Hydraulic feet can provide controlled and progressive ankle motion, particularly during heel strike and early stance. This can contribute to smoother loading, increased comfort and better adaptation to uneven terrain.
One limitation is the relatively limited dorsiflexion range found in many hydraulic designs. Once the available range is reached, further forward progression must be accommodated by the foot structure and the user's movement. Hydraulic damping also primarily dissipates mechanical energy rather than storing and returning it for propulsion.
Hydraulic systems themselves do not inherently store and return mechanical energy like an elastic spring. They primarily control movement by dissipating energy. Some hydraulic feet also incorporate carbon structures that can contribute to energy storage and return, but this is a separate function from the hydraulic mechanism itself.
No single prosthetic foot technology meets every user's needs.
Mobility goals, walking conditions, balance, comfort, functional capacity and clinical assessment all influence prosthetic foot selection. A qualified prosthetist can help compare suitable options.